3DGS-Calib: 3D Gaussian Splatting for Multimodal SpatioTemporal Calibration
IROS 2024 · Oral

Anchor a neural Gaussian representation to LiDAR geometry, then refine camera extrinsics and synchronization through differentiable rendering.
Method
3DGS-Calib anchors Gaussian centers to accumulated LiDAR points. A neural network predicts Gaussian attributes; differentiable rasterization jointly optimizes that representation and the camera extrinsics and time offsets. Coarse-to-fine voxelization accelerates calibration.

Results from the paper
LiDAR–camera calibration on KITTI-360
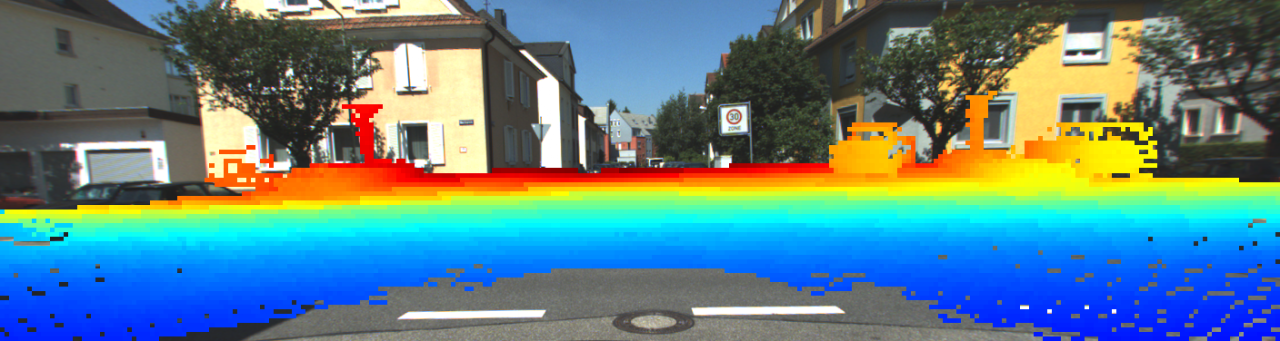
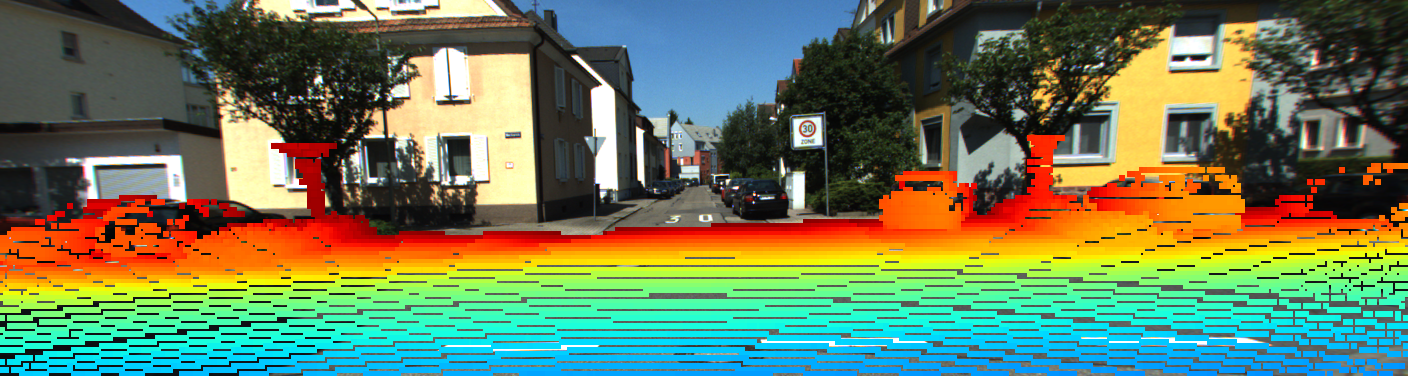
The paper evaluates the front-left camera against LiDAR on three KITTI-360 sequences. This experiment uses 3,000 training steps and progressive voxel resolution. All methods use the paper’s evaluation setup.
| Method | Rotation (°) ↓ | Translation (cm) ↓ | Training time (s) ↓ |
|---|---|---|---|
| Pandey et al. | 11.6 ± 6.5 | 90.7 ± 29.5 | — |
| LCCNet | 1.86 ± 0.09 | 89.5 ± 2.2 | — |
| MOISST | 4.92 ± 0.5 | 64.1 ± 6.8 | 1527 |
| MOISST w/ cropping | 6.01 ± 1.2 | 75.0 ± 3.7 | 860 |
| 3DGS-Calib | 0.45 ± 0.2 | 9.60 ± 2.1 | 216 |
Source: original paper table ↗
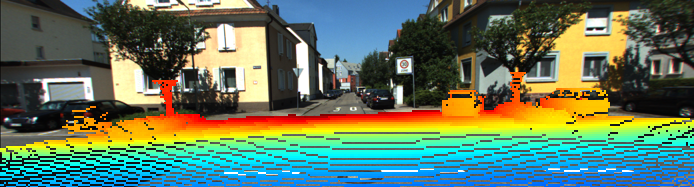
Qualitative calibration results
Pandey et al.
LCCNet
MOISST
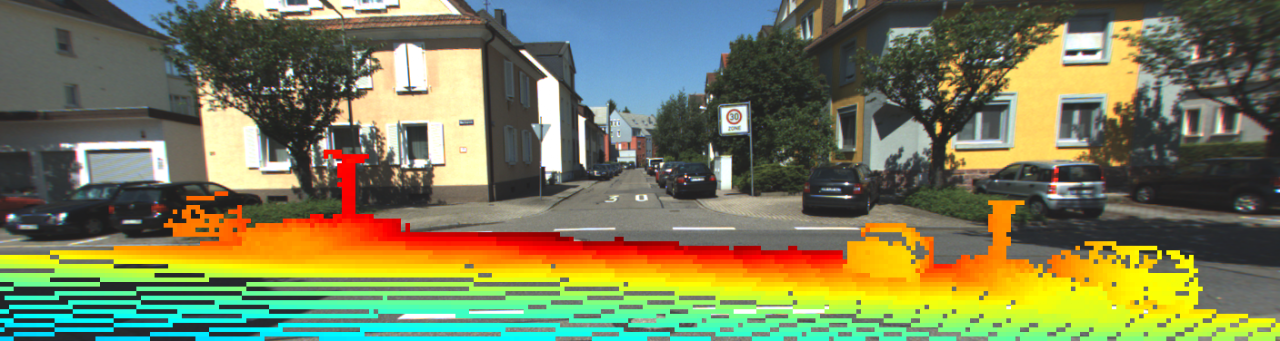
3DGS-Calib
Presentation & supplementary video
Supplementary video
Watch on YouTube ↗Research code
The open-source code release is coming soon. neural-calibration will provide MOISST, SOAC, 3DGS-Calib, MOISST++ and SOAC++ implementations, with raw-data setup, training and pose-export instructions. avoptim-benchmark will provide dataset processing and pose evaluation for KITTI-360, nuScenes, PandaSet and Waymo, supporting Original, refined and custom method poses.
The results shown here are reported paper results.
Citation
BibTeX
@misc{herau20243dgscalib,
      title={3DGS-Calib: 3D Gaussian Splatting for Multimodal SpatioTemporal Calibration},
      author={Quentin Herau and Moussab Bennehar and Arthur Moreau and Nathan Piasco and Luis Roldao and Dzmitry Tsishkou and Cyrille Migniot and Pascal Vasseur and Cédric Demonceaux},
      year={2024},
      eprint={2403.11577},
      archivePrefix={arXiv},
      primaryClass={cs.CV}
}